Movement
OLEM has 3 holonomic wheels which allow him to move in any direction and to freely combine movements in (x, y, theta).
NB: OLEM does his best to follow your instructions but if he can detect the edge of the board or table, he will make sure not to fall.
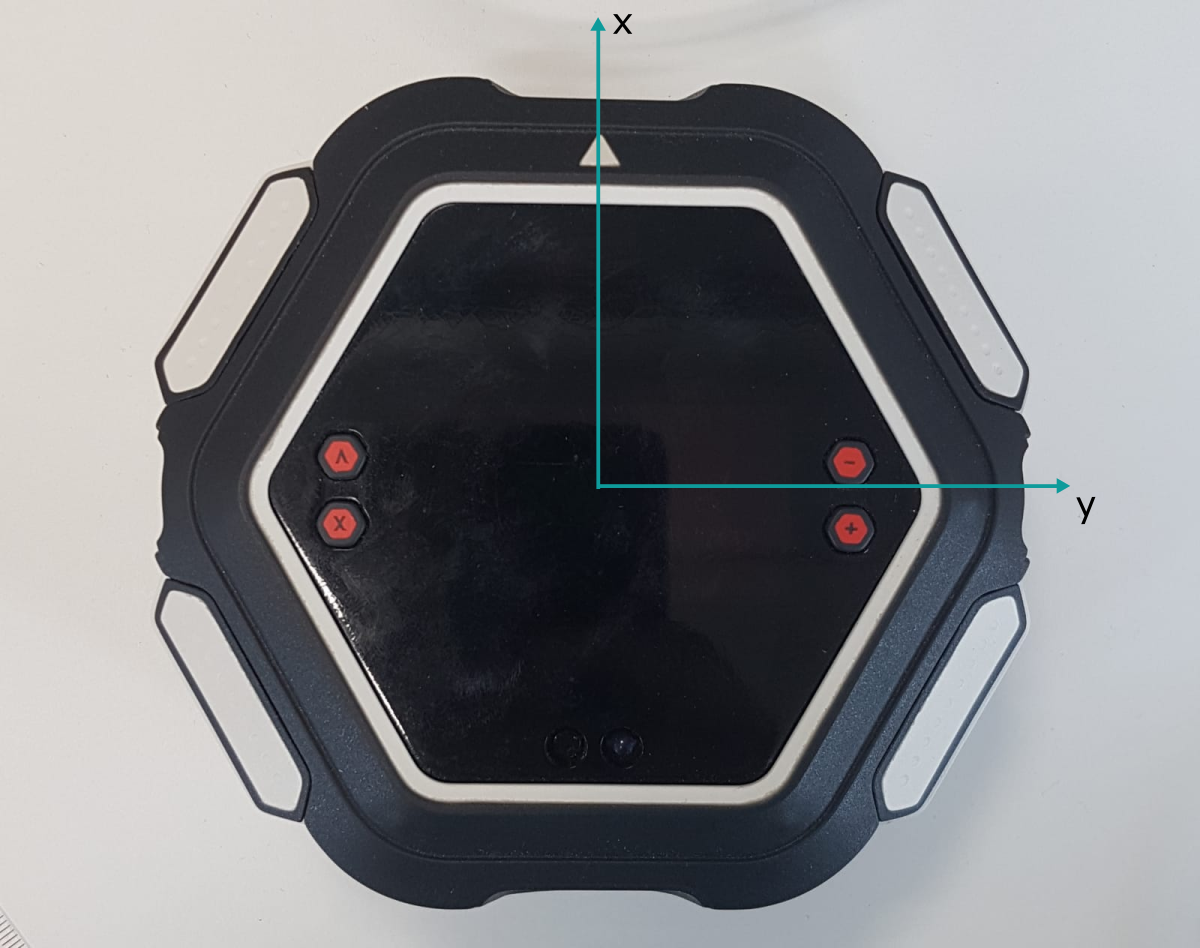
With the exception of wait_stop_moving(), all movement functions are non-blocking.
Movements can be requested in the cartesian or the polar space.
Movements can be requested using the current position as a referential or the starting position.
Examples
Speed control
OLEM goes back and forth 10 times, faster each time.
import olem

for i in range(10):
    print(i)
    olem.set_move_speed((i + 1) / 10)
    olem.move(100, 0, 0)
    olem.wait_stop_moving()
    olem.move(-100, 0, 0)
    olem.wait_stop_moving()
Moving in a square
OLEM goes around the same square twice, first with relative movements (move()) then with absolute ones (move_to()).
import olem

def square_path_relative(side_length, speed):
    """
    OLEM move in a square of specified width at requested speed
    always facing the same direction. OLEM's current position is
    used as the bottom left corner.
    :param side_length: square width in mm
    :param speed: between 0 and 1.0
    """
    olem.set_move_speed(speed)
    olem.move(side_length, 0, 0)
    olem.wait_stop_moving()
    olem.move(0, side_length, 0)
    olem.wait_stop_moving()
    olem.move(-side_length, 0, 0)
    olem.wait_stop_moving()
    olem.move(0, -side_length, 0)
    olem.wait_stop_moving()

def square_path_absolute(side_length, speed):
    """
    OLEM move in a square of specified width at requested speed
    always facing the same direction.
    :param side_length: square width in mm
    :param speed: between 0 and 1.0
    """
    olem.set_move_speed(speed)
    olem.move_to(side_length, 0, 0)
    olem.wait_stop_moving()
    olem.move_to(side_length, side_length, 0)
    olem.wait_stop_moving()
    olem.move_to(0, side_length, 0)
    olem.wait_stop_moving()
    olem.move_to(0, 0, 0)
    olem.wait_stop_moving()

square_width = 100
speed = 8 / 10

square_path_relative(square_width, speed)
square_path_absolute(square_width, speed)
Constants and functions
Constants
| Constant | Value | Description |
|---|---|---|
MOVE_CORR_X_MASK | 1 | Correction along the x axis, based on the lines of the tiles. |
MOVE_CORR_Y_MASK | 2 | Correction along the y axis, based on the lines of the tiles. |
MOVE_CORR_DISTANCE_MASK | 4 | Correction of the travelled distance, based on the spacing between the lines of the tiles. Requires MOVE_CORR_X_MASK. |
MOVE_CORR_IWJ_MASK | 32 | |
MOVE_CORR_ISS_MASK | 64 | |
MOVE_CORR_MSAFE_MASK | 128 | Refuse movements that would make OLEM fall off the board or table. |
move(x, y, rotation)
Move OLEM by the requested amount in cartesian space, relative to its current position.
Returns immediately, use wait_stop_moving() to wait for the end of the movement.
| Parameter | Description |
|---|---|
x | translation along the x axis in mm |
y | translation along the y axis in mm |
rotation | rotation in degrees |
move_to(x, y, orientation)
Move OLEM to a position in cartesian space, relative to its position at startup or at the last reset_position().
Returns immediately, use wait_stop_moving() to wait for the end of the movement.
| Parameter | Description |
|---|---|
x | position along the x axis in mm |
y | position along the y axis in mm |
orientation | orientation in degrees |
wait_stop_moving()
Block until OLEM stops moving.
The wait ends if the game is stopped.
stop_moving()
Stop the current movement.
turn(rotation)
Turn OLEM on itself by the requested angle.
Returns immediately, use wait_stop_moving() to wait for the end of the rotation.
| Parameter | Description |
|---|---|
rotation | rotation in degrees |
turn_to(orientation)
Turn OLEM on itself to the requested orientation.
Returns immediately, use wait_stop_moving() to wait for the end of the rotation.
| Parameter | Description |
|---|---|
orientation | orientation in degrees |
move_polar(distance, direction, rotation)
Move OLEM by the requested amount in polar space, relative to its current position.
Returns immediately, use wait_stop_moving() to wait for the end of the movement.
| Parameter | Description |
|---|---|
distance | distance to travel in mm |
direction | direction of the movement in degrees |
rotation | rotation in degrees |
move_to_polar(distance, direction, orientation)
Move OLEM to a position given in polar space, relative to its position at startup or at the last reset_position().
Returns immediately, use wait_stop_moving() to wait for the end of the movement.
| Parameter | Description |
|---|---|
distance | distance from the origin in mm |
direction | direction from the origin in degrees |
orientation | orientation in degrees |
move_towards(direction)
Move OLEM in a direction until stop_moving() is called.
| Parameter | Description |
|---|---|
direction | direction in degrees, relative to OLEM's current orientation |
set_move_speed(speed)
Set the speed of the movements requested after this call.
The default speed is 1.0.
| Parameter | Description |
|---|---|
speed | fraction of the maximum speed, from 0.0 to 1.0 |
get_move_speed()
Returns: speed set with set_move_speed(), from 0.0 to 1.0
get_position_x()
Returns: position along the x axis in mm, relative to the position at startup or at the last reset_position()
get_position_y()
Returns: position along the y axis in mm, relative to the position at startup or at the last reset_position()
get_orientation()
Returns: orientation in degrees, from 0 to 359
get_orientation_absolute()
Unlike get_orientation(), the orientation is not brought back between 0 and 359: it keeps counting full turns and can be above 360 or negative.
Returns: orientation in degrees, as an integer
reset_position()
Stop the current movement and use the current position as the new origin: position (0, 0) and orientation 0.
is_moving()
Returns: True if OLEM is moving, False otherwise
center_on_rotate(angle)
Re-center OLEM on its tile: OLEM turns on itself and uses the lines of the tile seen by its floor sensors to correct its position.
Returns immediately. Has no effect if a centering is already running.
| Parameter | Description |
|---|---|
angle | rotation to perform in degrees, 90 is recommended |
move_correction_enable(mask)
Enable automatic corrections of the movements.
| Parameter | Description |
|---|---|
mask | corrections to enable, combine MOVE_CORR_* constants with | |
move_correction_disable(mask)
Disable automatic corrections of the movements.
| Parameter | Description |
|---|---|
mask | corrections to disable, combine MOVE_CORR_* constants with | |